Skip to content

Darshak Panseriya

Perception Engineer

Figure
Fusion and tracking, INFRA-3DRC scene 9
Source
Sensor-Data-Fusion, 2026
Licence
INFRA-3DRC by Fraunhofer IVI, CC BY-NC 4.0
Camera-radar fusion and tracking on public roadside recordings (INFRA-3DRC): boxes matched to radar carry its range and radial speed, and each road user keeps a track ID.Code on GitHub

I build and validate ML perception on real sensors, with a background in suspension design and vehicle dynamics.

At Bosch I took a radar kick-detection function into series development in under seven months: data campaigns, the model, the detection system and a live demonstrator, then robustness in a customer vehicle and a passed OEM design review. Its architecture is filed as an internal invention disclosure.

Stuttgart · German C1 (telc) · English C1

Perception & ML

Radar sensing, sensor fusion and machine learning on real automotive hardware.

Robert Bosch GmbH · Oct 2025 to Sep 2026

Radar kick detection at Bosch

Hands-free tailgate opening, sensed by the digital-key radar already in the car. The tools behind it were adopted by Bosch teams in three countries.

RAM budget for the whole function, set by the microcontroller target
~100 KB
tailgate opensexisting digital-key radarkickkick zone

Drawn to explain; not Bosch data.

All perception work

Vehicle Design & Dynamics

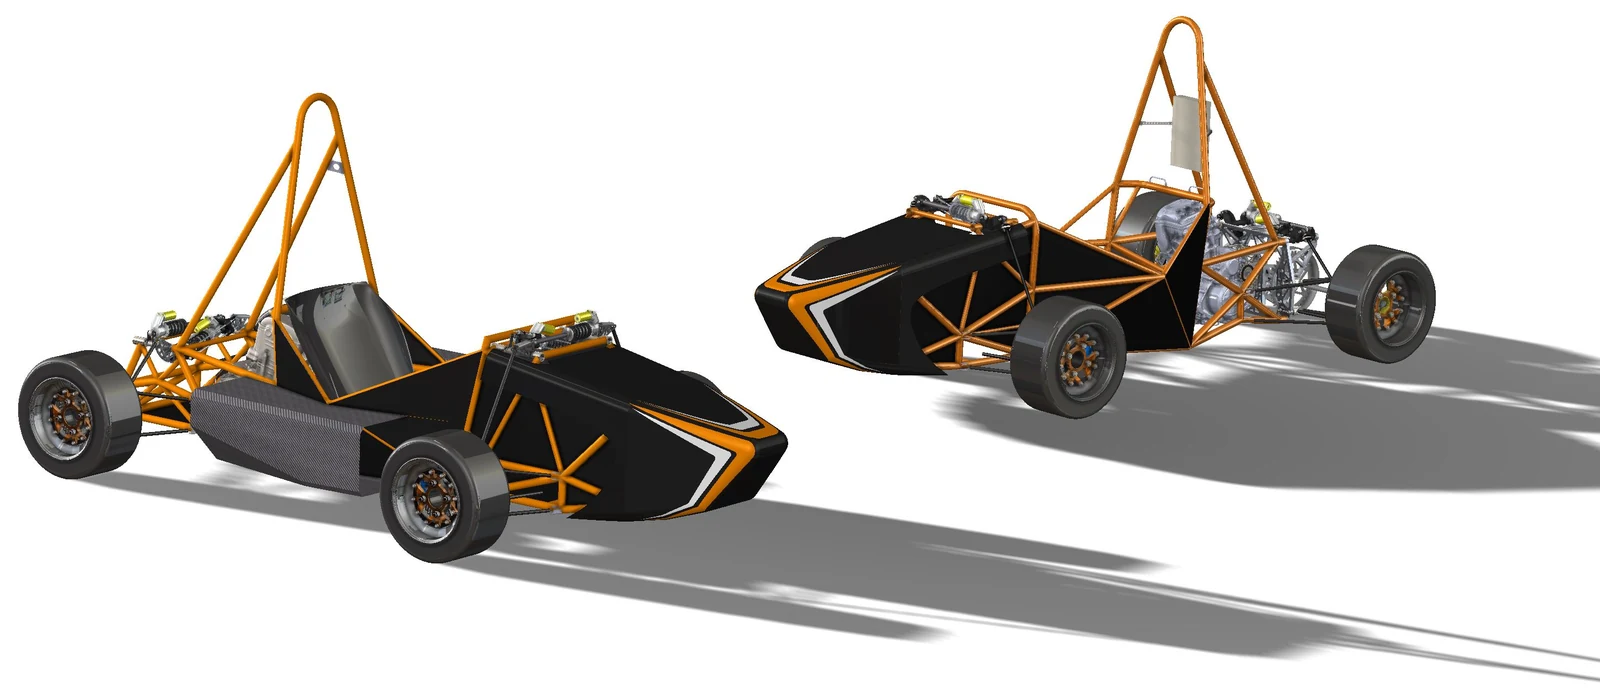
Where I started: suspension design and vehicle dynamics, on a micromobility platform and a Formula Student race car.

All vehicle design and dynamics work

Builder Lab. Tools I build to run my own work, with AI coding agents: DeckHQ (released on npm) and MechCopilot (open source).

Open the Builder Lab

About

I hold an M.Eng. in Automated Driving and Vehicle Safety from TH Ingolstadt and a B.Tech in Automobile Engineering from Parul University.

Full experience and CV